← orimiller.github.io

Robotics Engineer

Ori Miller

I build autonomy for robots that work around people: ground robots, drones, and quadrupeds that learn, perceive, and coordinate.

Albuquerque, NM · Open to relocation M.S. Computer Science (Robotics)
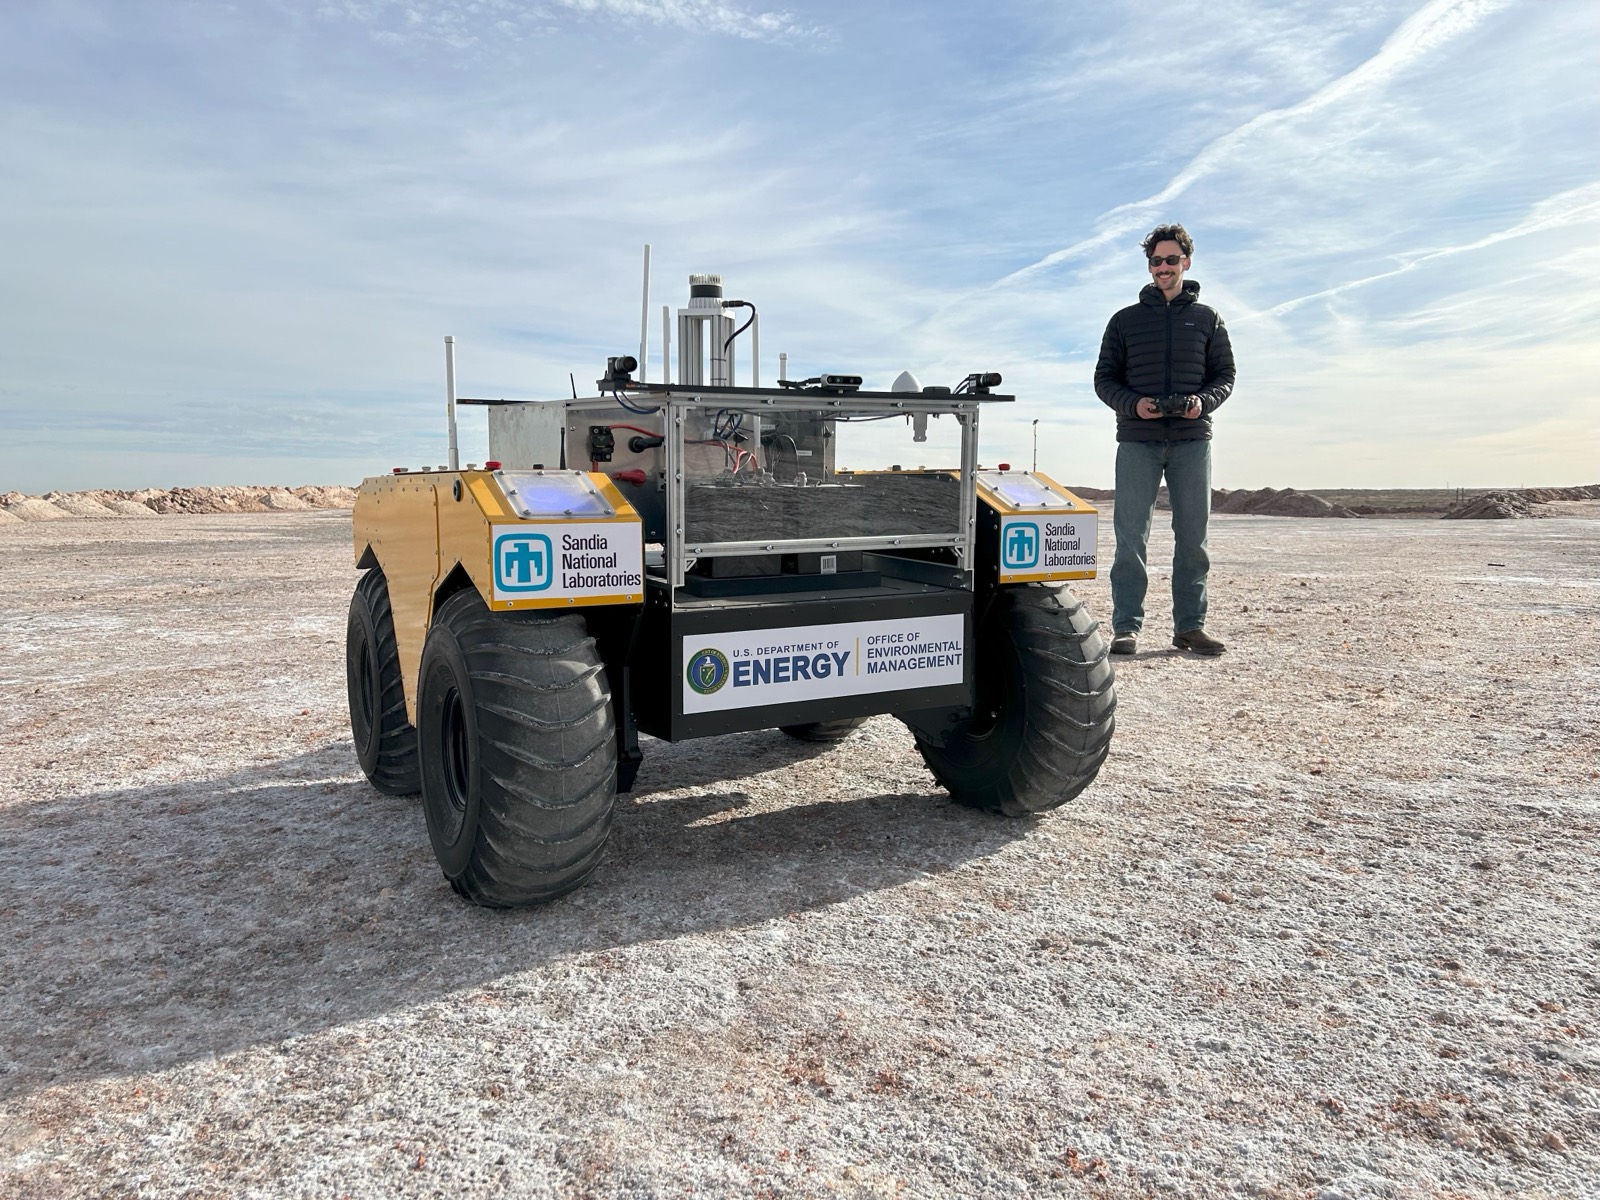
Ori Miller in the field with a Sandia National Laboratories Warthog ground robot, holding its controller
Field-testing a Warthog UGV · Sandia National Laboratories

5+ years

Robotics R&D

Sandia National Labs, Army Research Lab, University of Denver

4 papers

Published research

IEEE SSRR · ACM THRI · two ICRA workshops

5 platforms

Robot platforms run

Spot · Jackal · Warthog · TurtleBot · Crazyflie

Sim → Real

Learned policies, deployed

Took multi-agent RL from a 2D training world to a 3D ROS robot stack

What I bring

Reinforcement learning

Multi-agent policies (MADDPG) and the sim-to-real work to make them run in 3D.

Computer vision

Person detection, tracking, and localization; LiDAR–camera fusion; EKF.

Navigation

GPS-denied navigation in underground mines; SLAM and path planning.

Multi-robot systems

Air–ground teams that split the work: one robot sees, the other acts.

Human-robot interaction

AR interfaces for robot perception and user studies with real participants.

Experience

Autonomy & Counter-Autonomy Researcher

Sandia National Laboratories · Albuquerque, NM

Aug 2024 – Present
  • Autonomous testing: lead workflows that use Boston Dynamics Spot to evaluate and calibrate physical security sensors.
  • Red teaming: probe physical security systems with autonomous and semi-autonomous robots to expose adversarial exploitation paths.
  • Counter-autonomy: research techniques to detect, mitigate, and defend against adversarial robots.
Graduate Research Assistant

University of Denver · ARISE Lab

Mar 2022 – Aug 2024
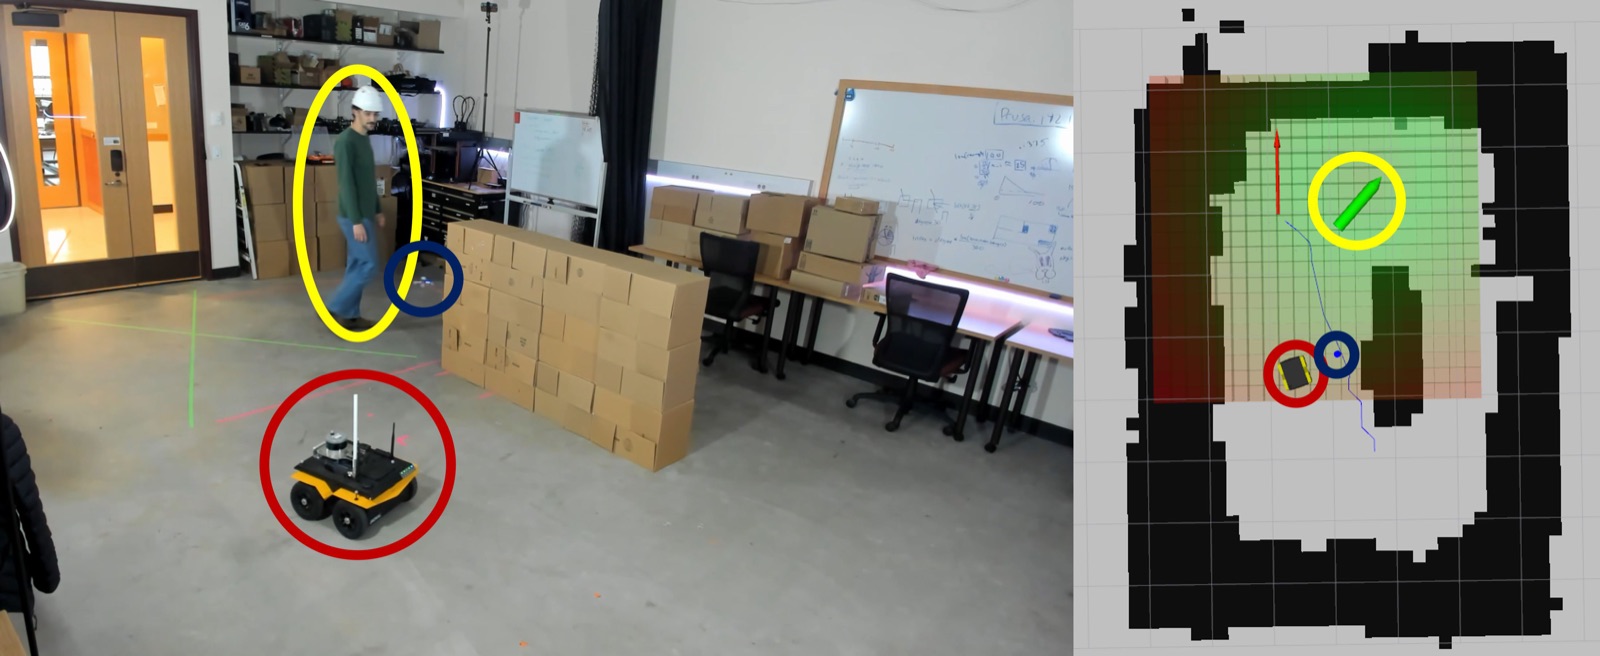
  • Multi-robot coordination: designed FORWARD-PF, a predictive waypoint-assignment algorithm that has a ground robot and a drone jointly follow a person. It completed 9 of 9 test paths, versus 7 for a multi-agent RL policy and 3 for a single-robot baseline, and reached the person 1.95× faster than the RL policy.
  • Reinforcement learning: trained MADDPG multi-agent policies and moved them from a 2D training world to a 3D ROS autonomy stack by redesigning their actions, observations, and coordinate scale.
  • Navigation: demonstrated GPS-denied, human-safe robot navigation in sparsely featured underground mines.
  • Hardware & publication: validated on a Clearpath Jackal and Crazyflie drone; published at IEEE SSRR 2024.

Journeyman Fellow

U.S. Army DEVCOM Army Research Laboratory · Adelphi, MD

Mar 2022 – Jun 2023
  • Built a heterogeneous air–ground robot system with person-following capabilities; presented at ICRA 2023 in London.

Undergraduate Research Assistant

University of Denver · ARISE Lab

Jan 2021 – Mar 2022
  • Developed person-following for a holonomic ground robot and ran HRI studies with human participants; awarded a Partners in Scholarship (PiNS) research grant.

Earlier: Software Engineer Intern, Trimble (2021): led an AWS event-notification service handling 250,000 messages a day (Python, Terraform, ECS, Lambda, SQS). Software Development Intern, Centene (2019): broke a monolith into Go microservices.

Featured project

Let's build robots that work with people.

I'm looking for robotics engineering roles in reinforcement learning, perception, navigation, multi-robot systems, and human-robot interaction.

Connect on LinkedIn